Corpo flexível
Flexão bidirecional e rotação de ±170° para alcance em ambientes restritos.
UBTECH context · multiple models →Precise handling and customised services in compact environments.
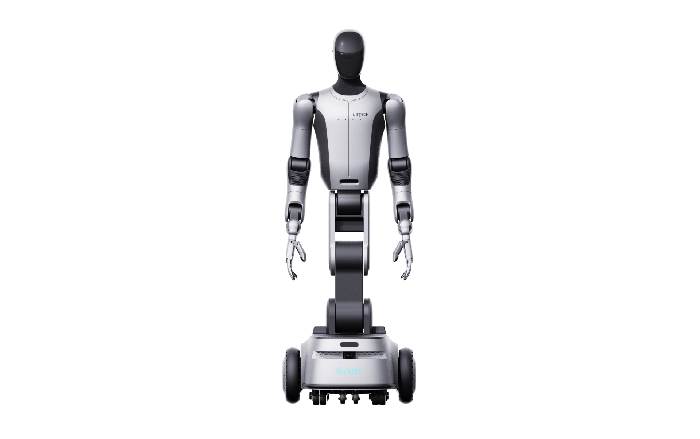
Full-size wheeled humanoid with wide motion range, dexterous hands, binocular vision and self-balancing base for industrial and service environments.
Technology designed to turn concrete use cases into measurable operations.
Flexão bidirecional e rotação de ±170° para alcance em ambientes restritos.
UBTECH context · multiple models →Mãos dextras de quarta geração para operações delicadas e repetíveis.
UBTECH context · multiple models →Perceção estereoscópica para localização, aproximação e manipulação.
UBTECH context · multiple models →Mobilidade eficiente, estabilidade e adaptação a terreno complexo.
UBTECH context · multiple models →Official videos organised by model and demonstration.
These videos present the ecosystem and several UBTECH robots. They are not exclusive demonstrations of this model; its specifications are listed in the technical sheet.
UBTECH shows the tightening system used in its factory. Manufacturing context, not a demonstration exclusive to one model.
Official video about the UBTECH factory operations management system.
UBTECH presents the connection between digital planning and its physical factory.
Official tour of UBTECH production and its automation ecosystem.
An overview of several robots and manufacturer demonstrations.
Coordination between robots presented by UBTECH.
A combined range presentation; consult each model’s technical sheet.
HUMATRIX validates environment, safety, integrations and success metrics before deployment.
Test picking and delivery with the intended tool at the workstation’s actual heights and distances.
Evaluate routes and visitor interaction, including handover to a member of staff.
Measure clearance at turns and station approaches with the load and arms in position.
Validate lighting and position parts as they will appear in operation to assess repeatability.
Plan the demonstration space, visitor flow and supervision of movement.
Test transitions between travel, stopping and handling along the intended route.
A robotics project does not end when the equipment is delivered.
Share the use case, environment and goals. We will prepare a technical and commercial proposal.
Technical information and images: official UBTECH page: UBTECH · Cruzr S2
Cruzr S2 uses a wheeled base and two arms to handle materials and supply workstations in compact spaces.